current work
Now
The projects that are still moving, followed by the latest notes from the workbench.
In progress
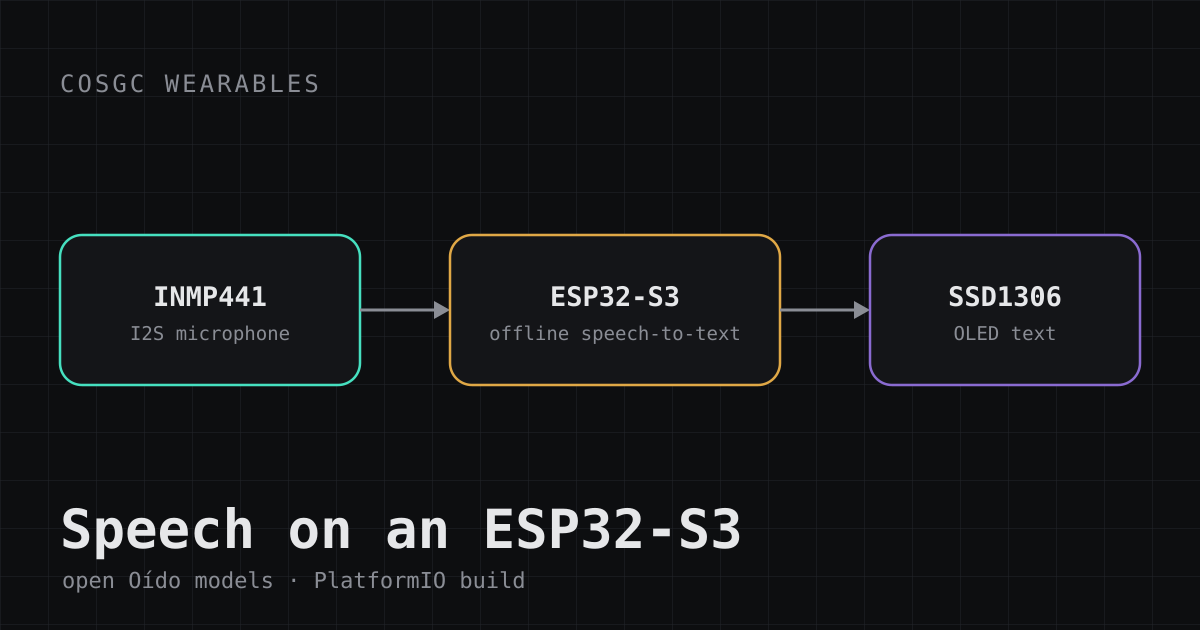
COSGC Wearables: Speech on an ESP32-S3
Offline speech-to-text on an ESP32-S3 wearable, built on the open Oído models. I added the PlatformIO build for an ESP32-S3 board with an INMP441 microphone and an OLED.
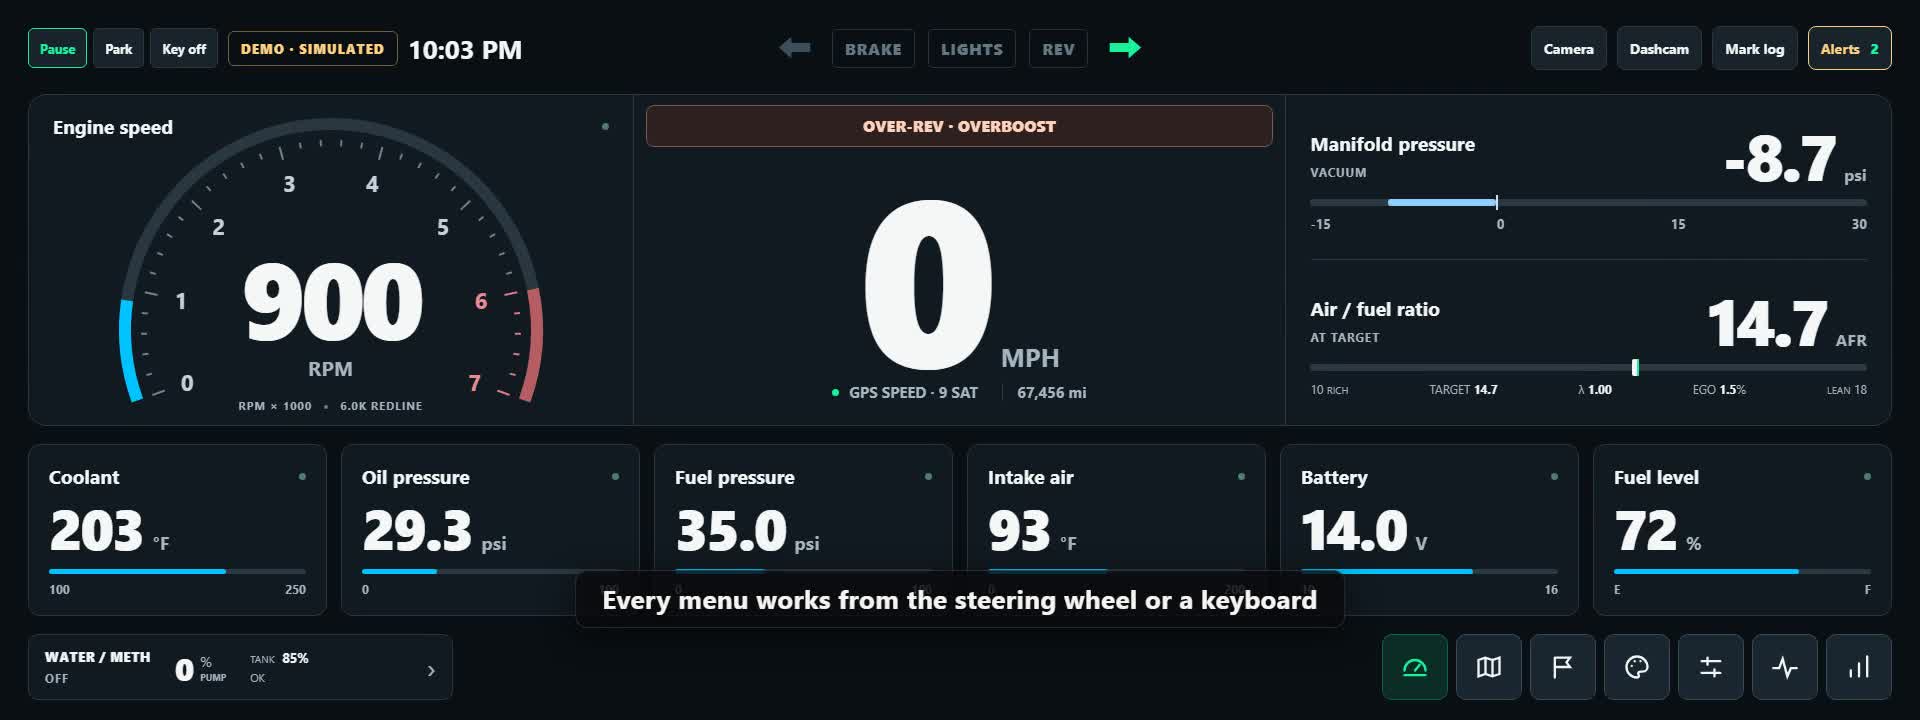
FrogDash: Digital Dash for My Foxbody Mustang
A custom 12.3-inch, 1920×720 Raspberry Pi 4 dashboard with live CAN data, GPS, GPIO, data logging, TunerStudio, UPS power protection, and purpose-built water/meth and knock monitoring.
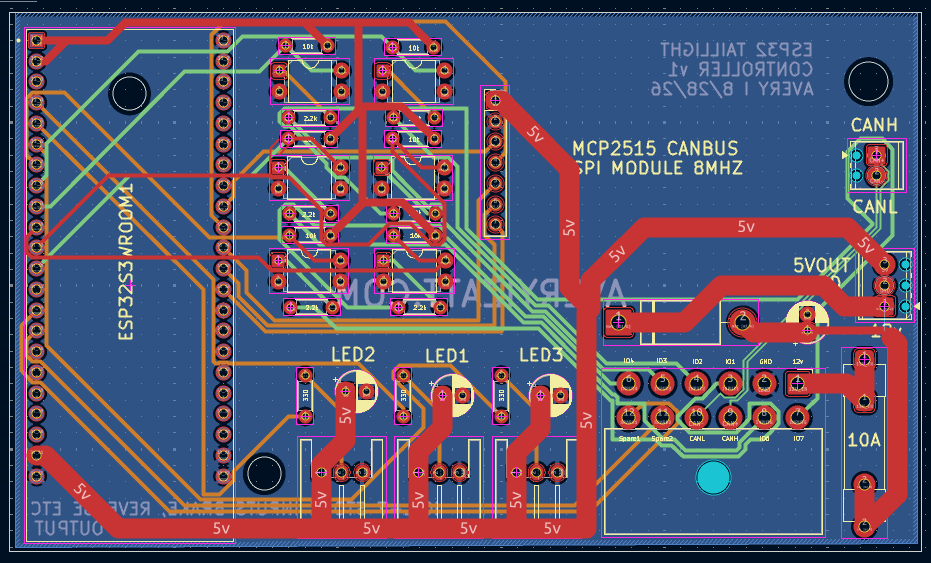
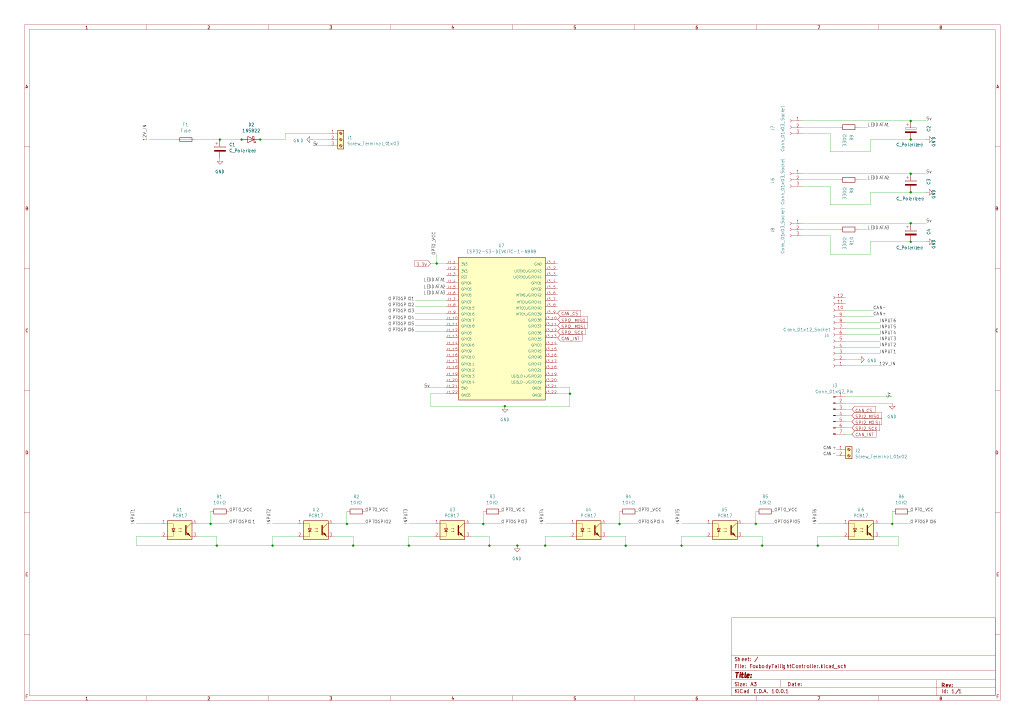
Fox Body Smart Taillight Controller
I moved my 760-pixel Foxbody taillight system to a custom ESP32-S3 PCB with isolated inputs, CAN, web controls, and safety logic.
Multi-Processor Automotive Control Network
I describe a distributed CAN network that links dedicated ESP32 controllers for my Mustang's dashboard, engine systems, and lighting.
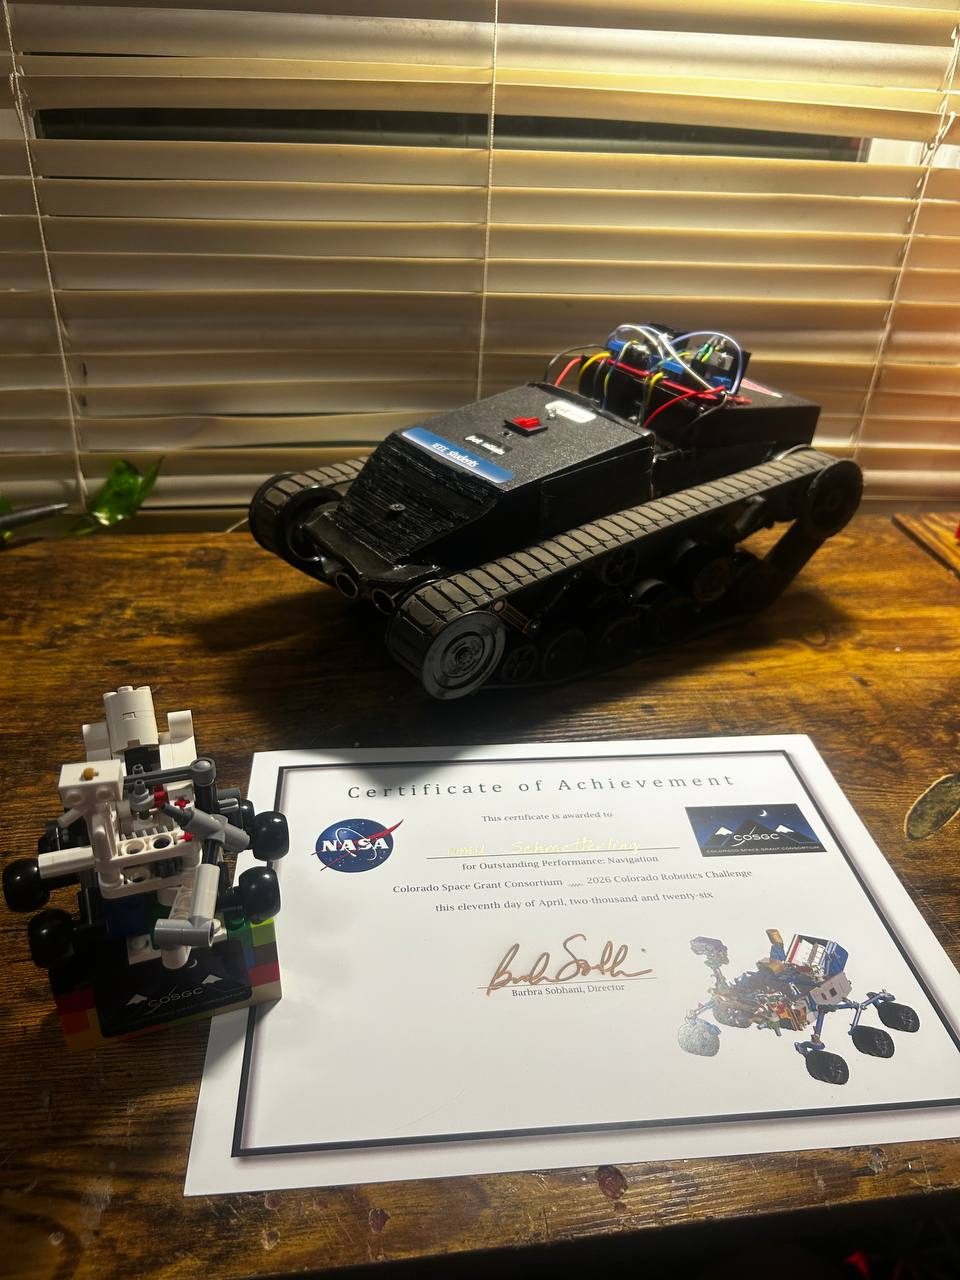
COSGC Autonomous Tank
The follow-up to our competition rover: a tracked robot with six ESP32 operating modes, a nine-layer motor safety system, IMU-based terrain handling and self-righting, plus a Raspberry Pi vision stack.
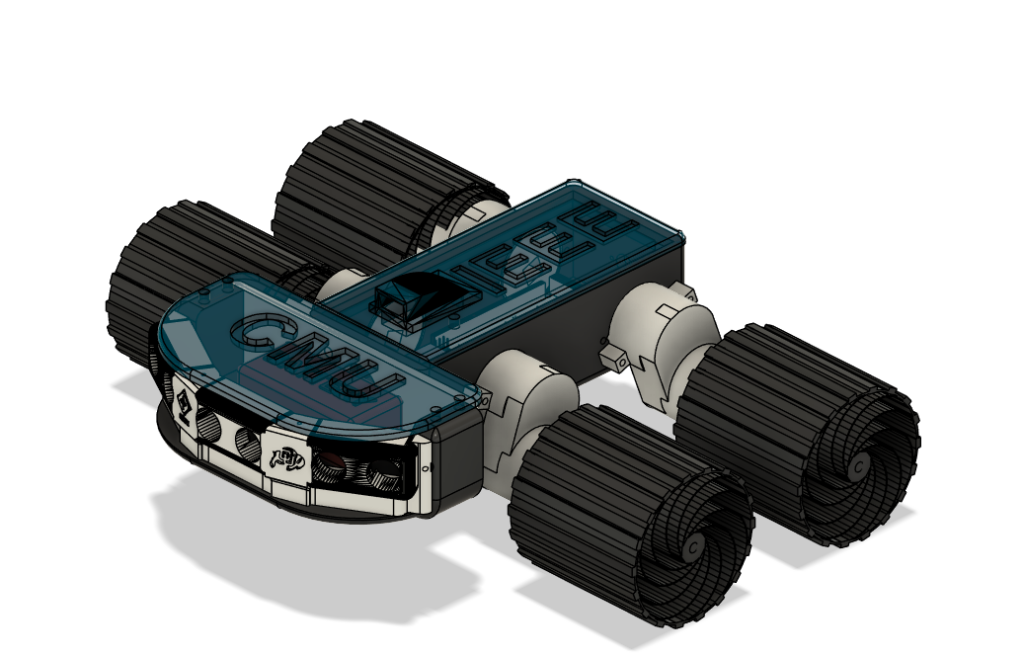
COSGC Planetary Rover
A skid-steer planetary rover built for the NASA-sponsored Colorado Space Grant Consortium Robotics Challenge. Our Colorado Mesa University team won Best in Class in the under 1.5 kg category in 2025.
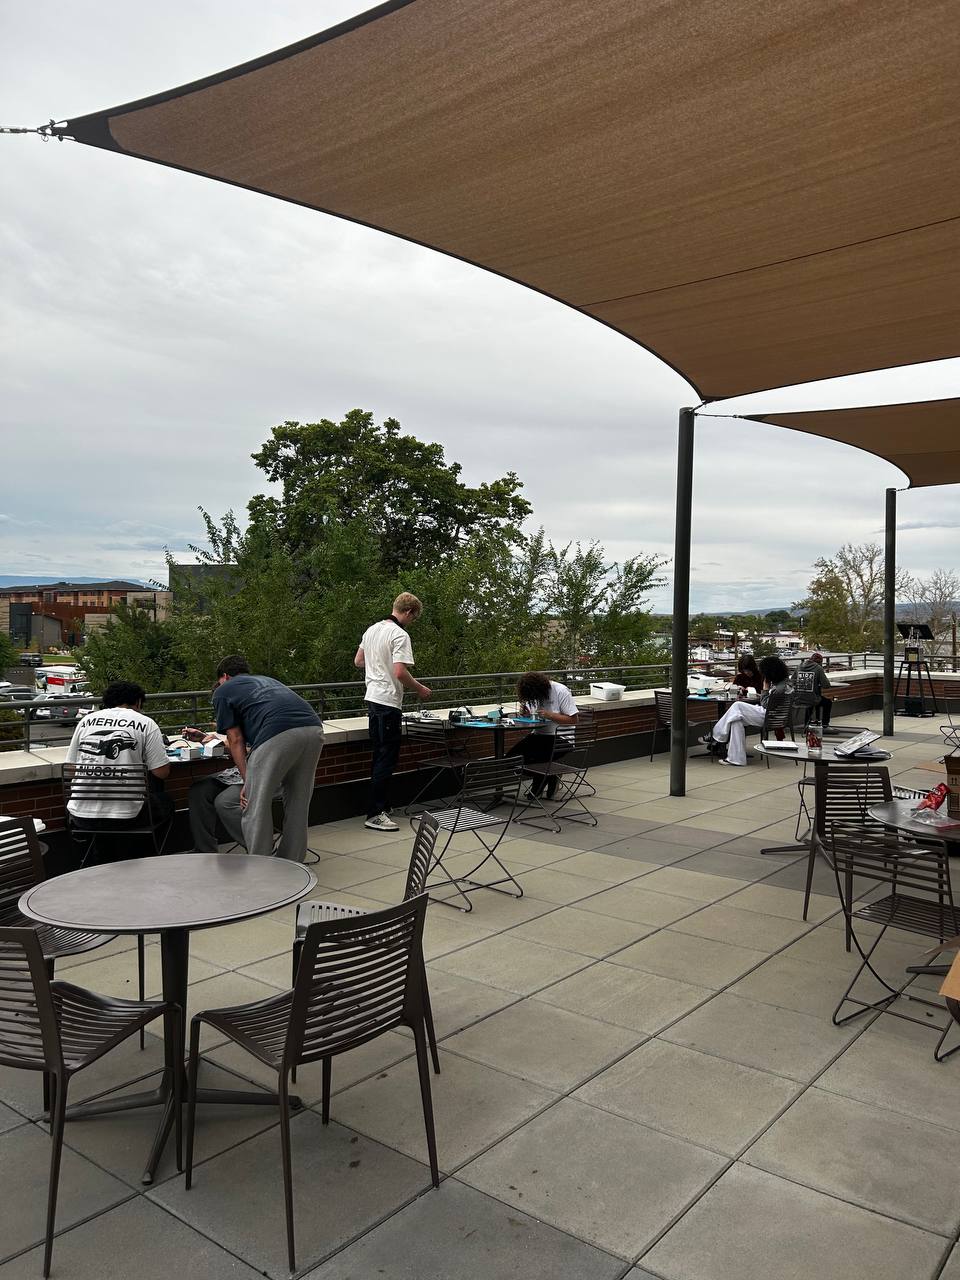
IEEE Student Branch at Colorado Mesa University
I'm president of the CMU IEEE student branch. We run technical projects, hands-on workshops like our soldering sessions, trips and outreach events, and the COSGC rover is the club's flagship build.
Latest updates
Homelab Update: OpenClaw, Local AI and What Changed
What changed in my homelab since the first post: Tailscale, separated machine roles, an OpenClaw assistant I run it with from Telegram, local AI models, verified backups and a website that now builds from Markdown.
FrogDash: A Digital Dash I Built for My Foxbody Mustang
A Raspberry Pi digital instrument cluster for my turbo Foxbody, and the engineering behind it: a shared CAN contract, MLG logging, trial-and-rollback updates, ignition power handling and firmware over CAN.
Foxbody Taillight Controller Update: Custom ESP32-S3 PCB and Firmware
I moved my 760-pixel Foxbody taillight system to a custom ESP32-S3 PCB with isolated inputs, CAN, web controls, and safety logic.
Multi Processor Automotive Control Network
I describe a distributed CAN network that links dedicated ESP32 controllers for my Mustang's dashboard, engine systems, and lighting.
First PCB Update: Firmware
I developed modular firmware for my ESP32-S3 robotics board, adding motion control, sensors, a TFT interface, Wi-Fi, and BLE.